The world of robotics is an ever-evolving field, and one of the key challenges lies in replicating the agility and power of biological systems. In this article, we delve into the fascinating journey of [Food for Robots], a creator who embarked on the task of building a joint-mounted actuator for a walking robot, an endeavor that sheds light on the intricate world of robotics engineering.
The Challenge of Imitating Nature
Nature has endowed biological systems with an incredible advantage: muscles. These dynamic tissues provide a combination of strength, speed, and compactness that is hard to replicate in robotic systems. This is especially true for walking robots, which, unlike their biological counterparts, cannot distribute actuators along their limbs but must concentrate them at the joints.
[Food for Robots]'s Journey
[Food for Robots] set out to create an actuator that would power a walking robot with specific requirements: compactness, lightweight design, and the ability to generate 20 Newton-meters of torque. Their initial attempt involved a largely 3D-printed actuator, but pushing beyond 10 Nm of torque proved challenging, with various components breaking.
Iteration and Innovation
The second iteration saw a shift from 3D printing to machining with aluminum. This allowed for a more robust design, and a planetary gearbox replaced the Capstan drive, increasing strength within the CNC's limitations. The control board utilized a small magnet attached to the motor's rotor to read the position, and the controller was reused from the previous actuator.
Overcoming Obstacles
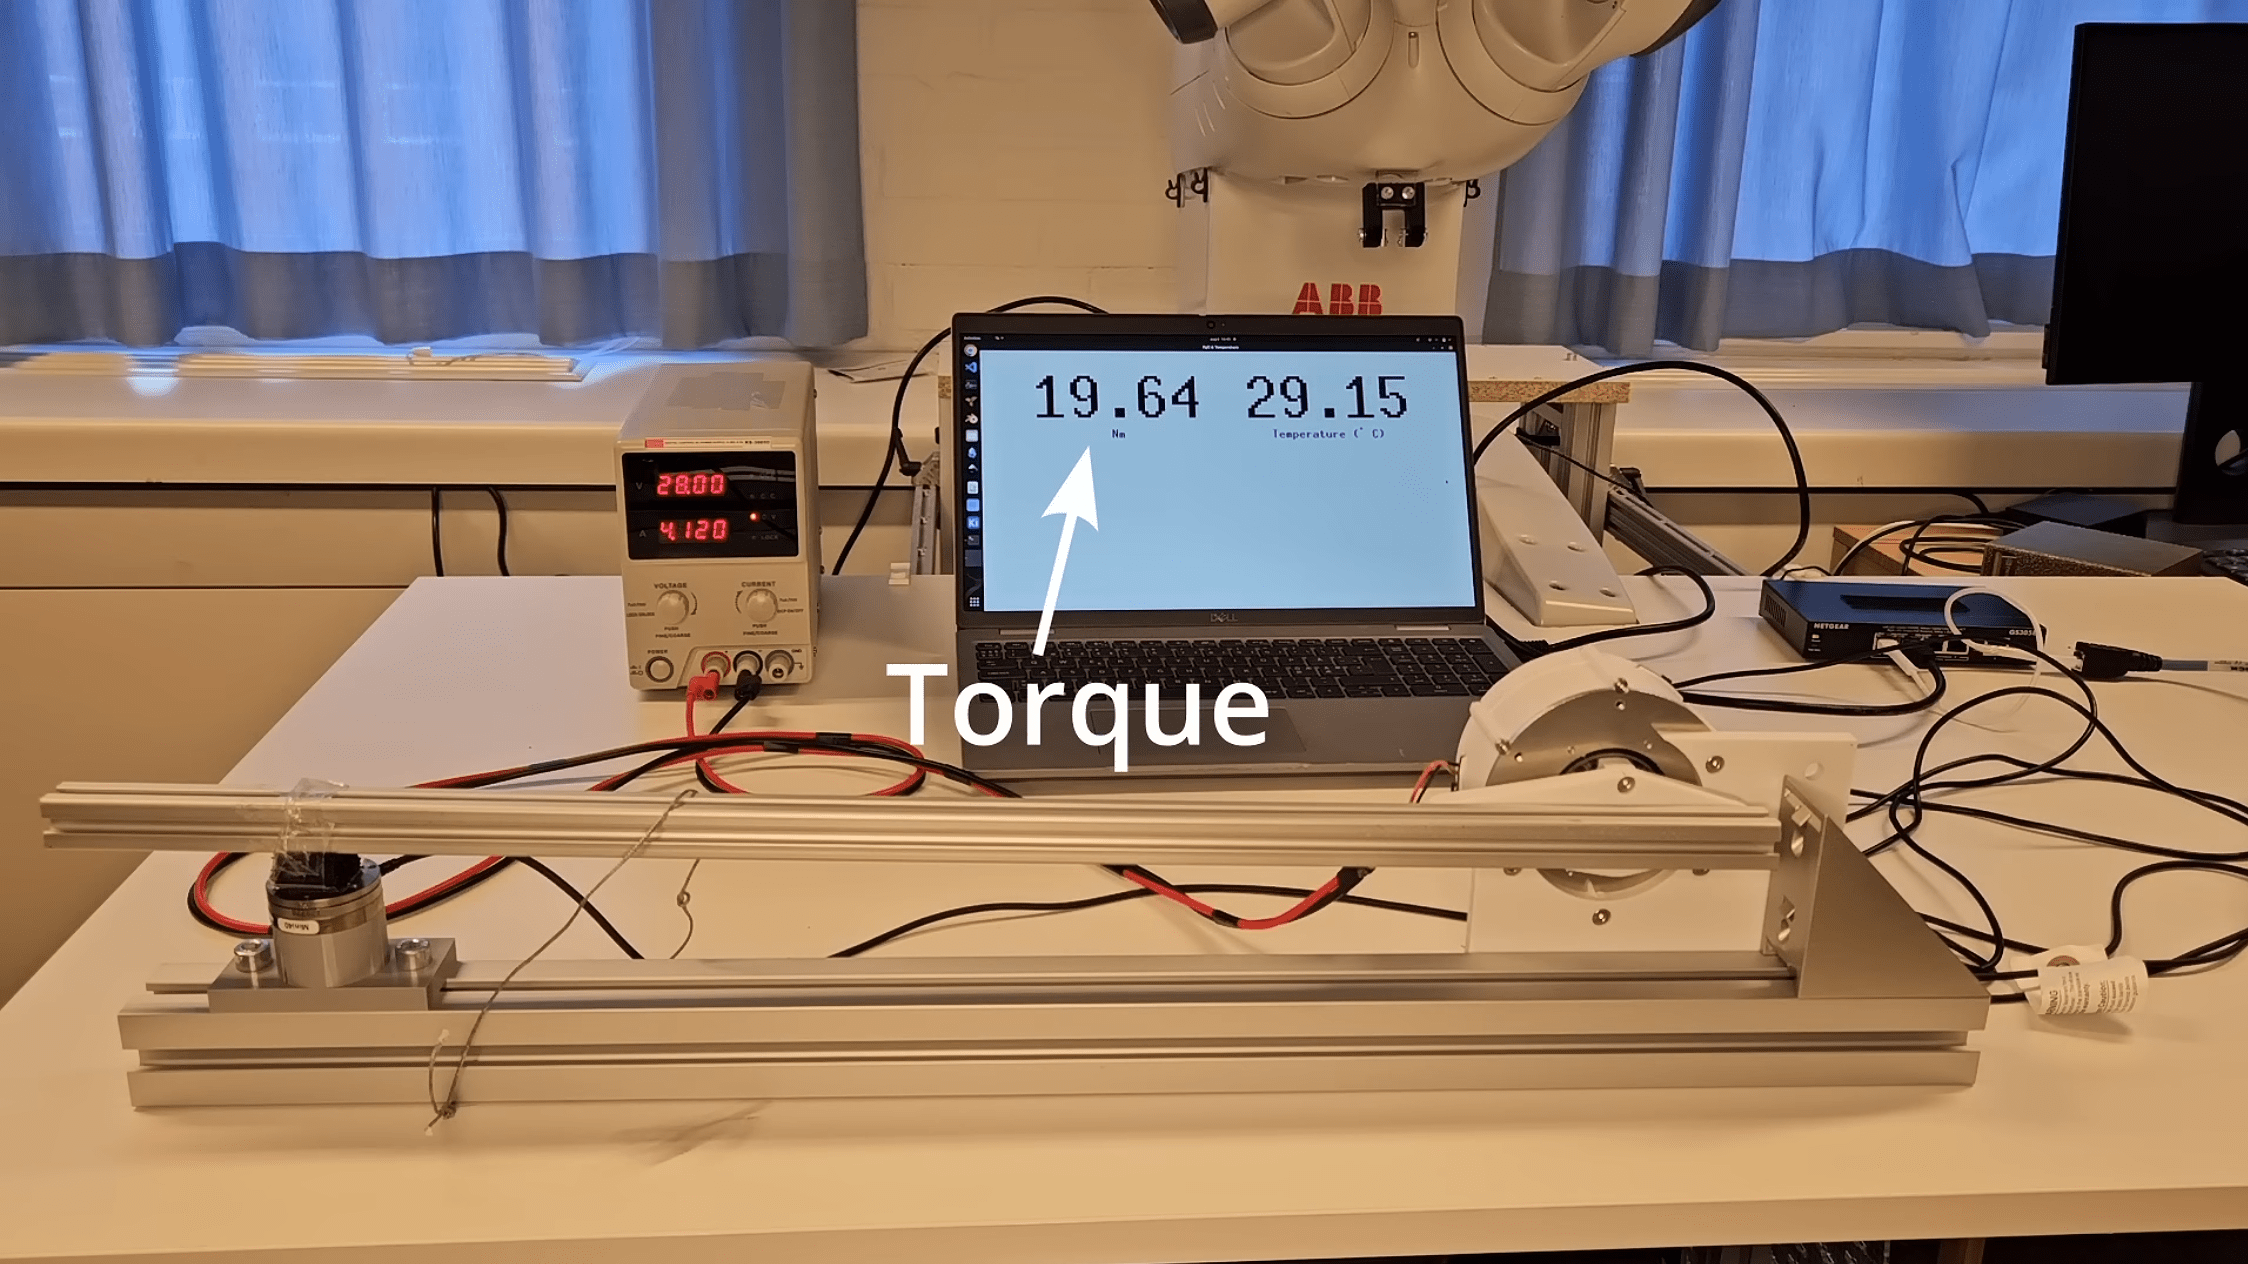
In the initial test, the actuator fell short of the desired torque, despite doubling the stator's thickness. A clever investigation revealed that the issue lay in the number of windings, which, while increasing thickness, also increased resistance due to a reduced number of wires. A simple adjustment to the field-oriented control algorithm, increasing current limits, solved the problem, achieving the desired 20 Newton-meters.
Exploring Alternatives
For those interested in similar builds, there are other remarkable quasi-direct drive actuators worth exploring. From compact cycloidal drives to DIY robot actuators, the world of robotics engineering is brimming with innovative solutions.
Final Thoughts
The journey of [Food for Robots] highlights the intricate balance between design, materials, and control algorithms in robotics engineering. It's a fascinating reminder of the challenges and rewards of pushing the boundaries of what's possible. As we continue to explore and innovate, the future of robotics looks increasingly bright and full of potential.